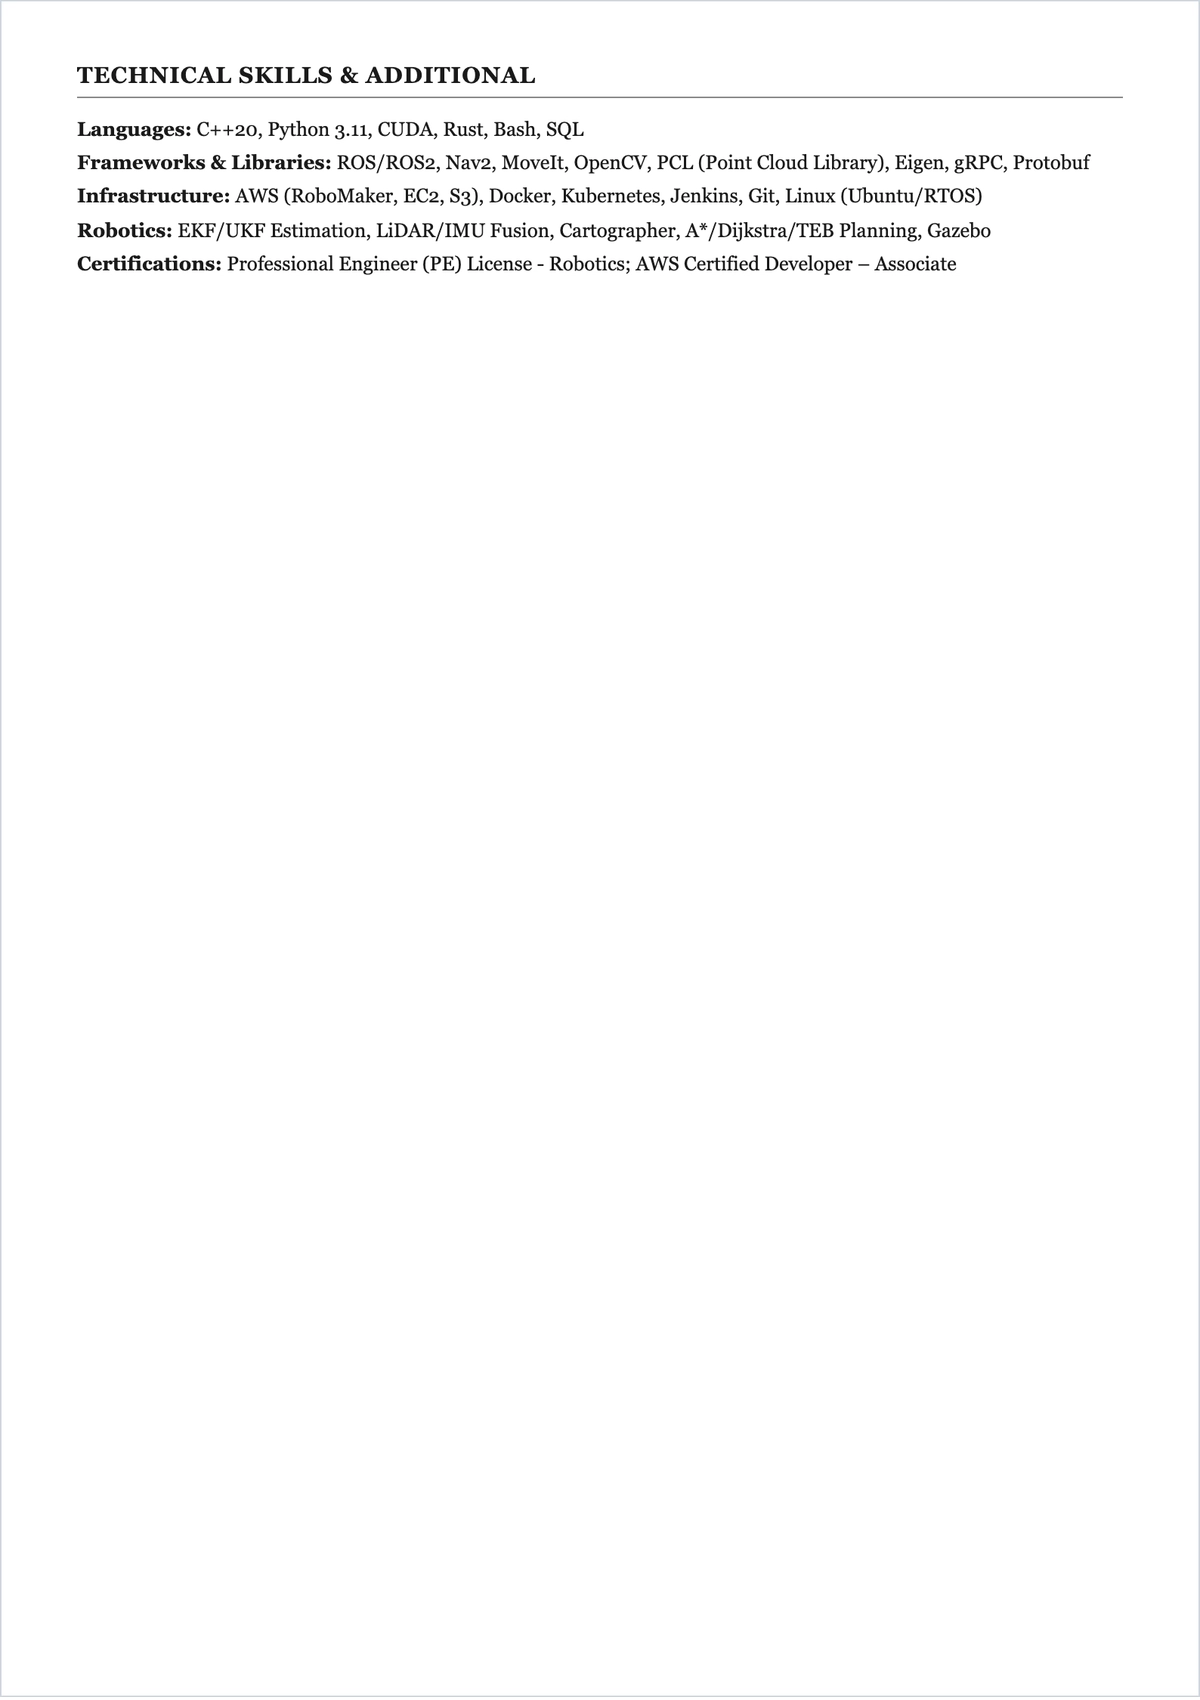
A Robotics Software Engineer Resume presents your ROS, C++, SLAM, and motion-planning skills for robotics roles, built with Template.net's AI-powered resume builder.
A Robotics Software Engineer Resume presents your ROS, C++, SLAM, and motion-planning skills for robotics roles, built with Template.net's AI-powered resume builder.
How to Create a Robotics Software Engineer Resume for Free?
- Customize a Free TemplateStart with this free editable and printable Robotics Software Engineer Resume template and personalize it online for a job application, career change, or research internship. (or )
- Generate an ATS-Optimized Robotics Software Engineer Resume with AIDescribe your experience or upload your current CV, and AI builds an editable, ATS-optimized Robotics Software Engineer Resume highlighting ROS/ROS2, C++/Python, SLAM, computer vision, and motion planning, ready to review.
- Edit in the HTML5 EditorAdjust your name, contact details, photo, project experience, robotics skills, education, and layout in the drag-and-drop HTML5 editor.
- Download a Printable PDFDownload your completed Robotics Software Engineer Resume as a printable PDF for job applications, interviews, or record keeping.
- Share a Link to Apply OnlinePublish your Robotics Software Engineer Resume with a shareable link so recruiters and hiring managers can view it directly.
Robotics Software Engineer ATS Resume Keyword Optimization
Optimize your resume with these keywords to get picked up by Applicant Tracking Systems — ROS/ROS2, C++, Python, SLAM, Motion Planning, Path Planning, Sensor Fusion, Kalman Filters, Computer Vision, OpenCV, LiDAR, Gazebo Simulation, Real-Time Systems, Embedded Systems, Control Systems, PID Controllers, Kinematics, Machine Learning, Robot Operating System, CI/CD Pipelines, Git/Version Control, Linux.